Description
Build your own tank. Learn how robots really move.
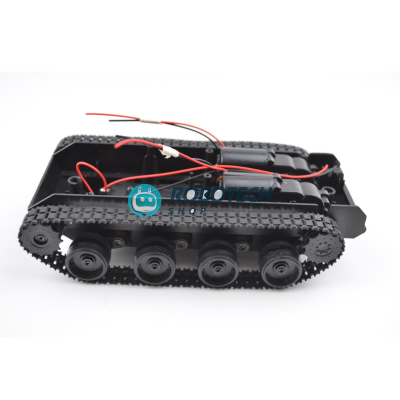
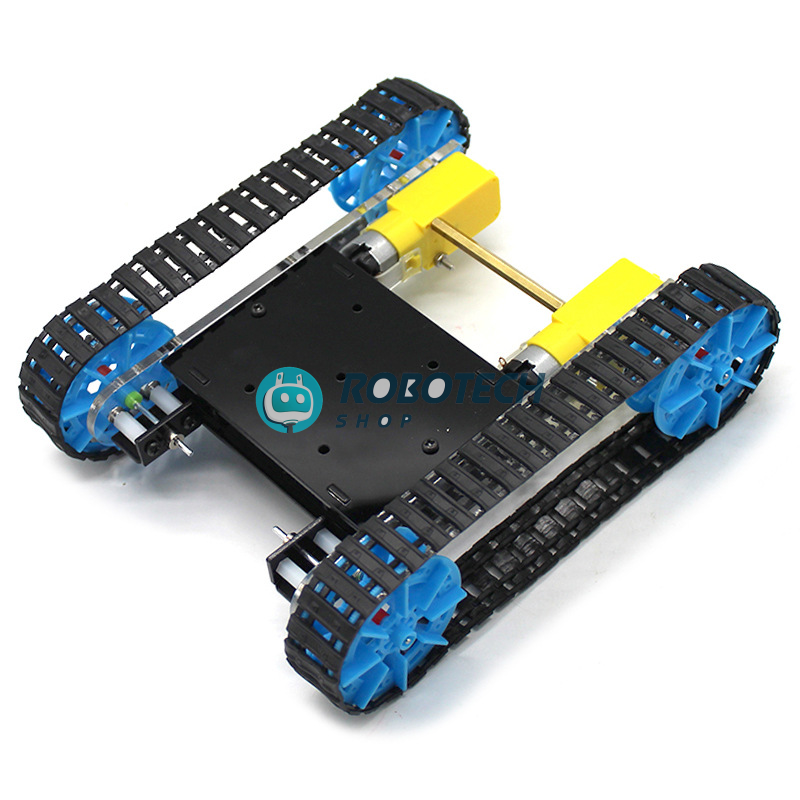
A tracked crawler chassis you assemble yourself, with two TT geared motors, four main wheels and crawler tracks. Add an Arduino or ESP32, a motor driver and a battery, and drive over carpet, grass and rough ground that stops ordinary wheeled robots.
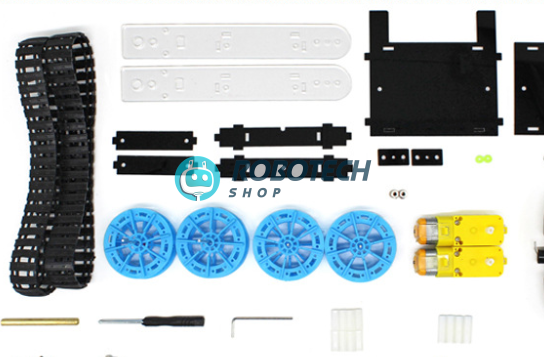
এই DIY ট্যাঙ্ক রোবট চেসিস কিটটি disassembled অবস্থায় আসে, অর্থাৎ parts আলাদা থাকে এবং আপনাকে নিজে assemble করতে হবে। Arduino ও ESP32 প্রজেক্ট, স্কুল সায়েন্স প্রজেক্ট এবং STEM শেখার জন্য এটি খুবই উপযোগী।
See how a tank steers
A tank has no steering wheel. It turns by running its left and right tracks at different speeds or directions. Choose a move to see what each track does.
With one motor on each side, your code controls both tracks independently.
Specifications
| Product | DIY Tank Robot Chassis Kit, disassembled tracked crawler platform |
|---|---|
| Drive | 2 × TT geared motors, with independent left and right drive |
| Tracks and wheels | Crawler tracks with 4 main wheels |
| Assembled size | About 190 × 160 × 55 mm |
| Motor voltage | 3V to 6V DC, typical for TT motors |
| Assembly | Required. The kit comes as separate parts. |
| Mounting | Multiple mounting points for electronics and sensors |
| Works with | Arduino, ESP32 and other robotics controllers |
| In the box | Crawler tracks, 4 main wheels, 2 TT geared motors and chassis assembly parts |
| Not included | Controller, motor driver and battery (sold separately unless specified) |
What you will also need
| Controller | Arduino UNO or Nano, or an ESP32 board |
|---|---|
| Motor driver | L298N, L293D or a similar dual DC motor driver |
| Battery | A 6V to 8.4V pack, such as 4 × AA or 2 × 18650 cells |
| Extras | Jumper wires, plus optional sensors such as the HC-SR04 ultrasonic sensor, an HC-05 Bluetooth module or an ESP32-CAM |
What you can build
One chassis, many robots.
Obstacle-avoiding tank
Add an ultrasonic sensor and let the tank find its own way around a room.
Phone-controlled tank
Drive it with an HC-05 Bluetooth module and a phone app.
ESP32 Wi-Fi crawler
Control it from a web page on your phone.
Camera tank
Add an ESP32-CAM for a live video robot.
Rough-terrain explorer
Tracks grip carpet, grass and uneven ground better than plain wheels.
Science fair project
A hands-on build that teaches mechanics and electronics together.
Wiring it to Arduino and L298N
| L298N pin | Connect to |
|---|---|
| ENA, IN1, IN2 (left motor) | Arduino D5, D7, D8 |
| ENB, IN3, IN4 (right motor) | Arduino D6, D9, D10 |
| OUT1, OUT2 | Left TT motor |
| OUT3, OUT4 | Right TT motor |
| 12V terminal and GND | Battery pack. Join the L298N GND to the Arduino GND. |
Mind the voltage: TT motors are rated for about 3V to 6V, and the L298N uses up roughly 2V. A 7.4V pack (2 × 18650) gives the motors a safe level. Do not connect them directly to a 12V supply.
Basic Arduino code
This sketch drives forward, spins left, spins right, reverses and stops, using the pins from the table. If a side runs the wrong way, swap that motor’s two wires.
const int ENA = 5, IN1 = 7, IN2 = 8;   // left motor
const int ENB = 6, IN3 = 9, IN4 = 10;  // right motor
void setup() {
  int pins[] = {ENA, IN1, IN2, ENB, IN3, IN4};
  for (int i = 0; i < 6; i++) pinMode(pins[i], OUTPUT);
}
// speed: -255 (full reverse) to 255 (full forward)
void drive(int left, int right) {
  digitalWrite(IN1, left >= 0 ? HIGH : LOW);
  digitalWrite(IN2, left >= 0 ? LOW : HIGH);
  analogWrite(ENA, abs(left));
  digitalWrite(IN3, right >= 0 ? HIGH : LOW);
  digitalWrite(IN4, right >= 0 ? LOW : HIGH);
  analogWrite(ENB, abs(right));
}
void loop() {
  drive(200, 200);    delay(2000);  // forward
  drive(-200, 200);   delay(700);   // spin left
  drive(200, -200);   delay(700);   // spin right
  drive(-200, -200);  delay(1500);  // backward
  drive(0, 0);        delay(2000);  // stop
}
Lower the 200 values for slower, gentler movement. For ESP32, use the same logic with your own PWM-capable pins.
Questions buyers ask
Is the chassis already assembled?
No. This is the disassembled version, so the parts come separately and you assemble them. That is what makes it a great learning project.
Are the controller, motor driver and battery included?
No. Those are sold separately unless the listing says otherwise. See the “What you will also need” list above.
Which controllers work with it?
Arduino UNO and Nano, ESP32 and most other robotics boards. You need a motor driver between the board and the motors.
Which motor driver should I use?
The L298N is the most popular and the easiest to find. L293D and similar dual DC motor drivers also work.
My tank drives in circles or pulls to one side. Why?
The two motors may be wired in opposite directions, or one side may be running slower. Swap the wires of the reversed motor, and adjust the speed values in your code to balance both sides.
Can it carry extra weight?
It is a light chassis for electronics and sensors. Keep the load modest so the TT motors run well.
Do you deliver outside Dhaka?
Yes, we deliver all over Bangladesh.
Related searches
English: tank robot chassis price in Bangladesh, DIY tracked chassis BD, crawler robot kit Bangladesh, Arduino tank chassis Dhaka, TT motor tank kit BD, ESP32 robot chassis Bangladesh, robotics chassis kit Bangladesh, STEM robot kit BD, school science project robot Bangladesh, handmade technology project, student robotics kit, robotics shop Bangladesh
Banglish: tank robot chassis dam koto, crawler robot kit kothay pabo, Arduino tank banano, robot chassis price BD, school project robot kit Dhaka
বাংলা: ট্যাঙ্ক রোবট চেসিস দাম, ক্রলার রোবট কিট, আরডুইনো ট্যাঙ্ক রোবট, রোবট চেসিস বাংলাদেশ, স্কুল সায়েন্স প্রজেক্ট রোবট, রোবটিক্স শপ ঢাকা